Sensor solutions for automated guided vehicles (AGVs) in intralogistics
In intralogistics, particularly in distribution, mobile vehicles are used primarily for transport tasks. The spectrum ranges from simple tow trucks that follow predetermined routes to automated guided vehicles (AGV), which navigate autonomously through distribution centers, warehouses, and order-picking areas. They automatically pick up and deliver goods and respond to changes in their environment.
Employee safety is the top priority. Appropriate safety concepts and suitable sensor solutions must ensure that people and vehicles work together reliably and safely.
Sensors for automated guided vehicles
The requirements for sensor technology in mobile transport vehicles are diverse and are largely determined by the respective operating environment and specific application. As automated guided vehicles (AGVs) perform a range of different tasks, their sensor and detection systems must be tailored to their specific requirements.
Key application areas include detection and positioning for the reliable identification of objects and precise position determination; occupational safety for safe operation in dynamic environments involving people and systems; and navigation for orientation, obstacle detection, autonomous path planning, and the precise determination of the sensor’s own position in space.
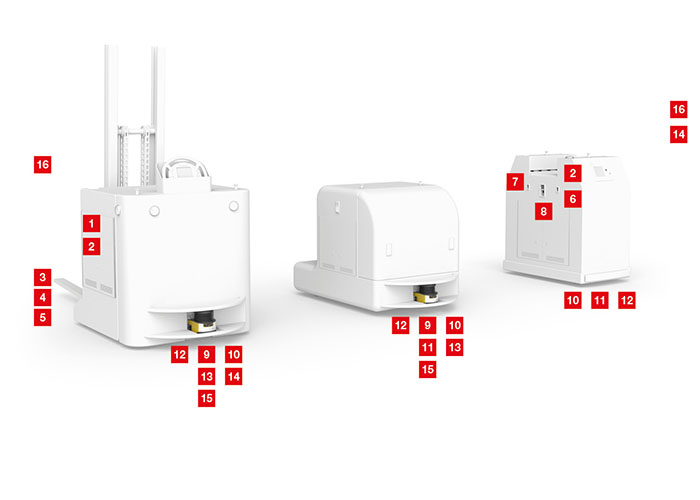
Click on the numbered applications to learn more about the respective sensor solutions.
Applications of sensors in driverless transport systems
The sensor technology used in mobile transport vehicles can be categorized into several areas of application. These include load detection, detection of end positions on the lifting unit, monitoring the availability of transfer points, and vehicle positioning. Other key areas include path control and obstacle detection, as well as monitoring the vehicle’s surroundings to ensure employee safety.
Detection and positioning applications
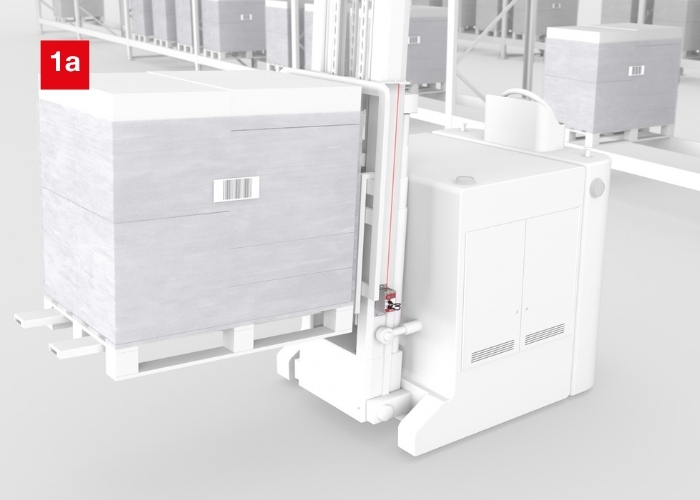
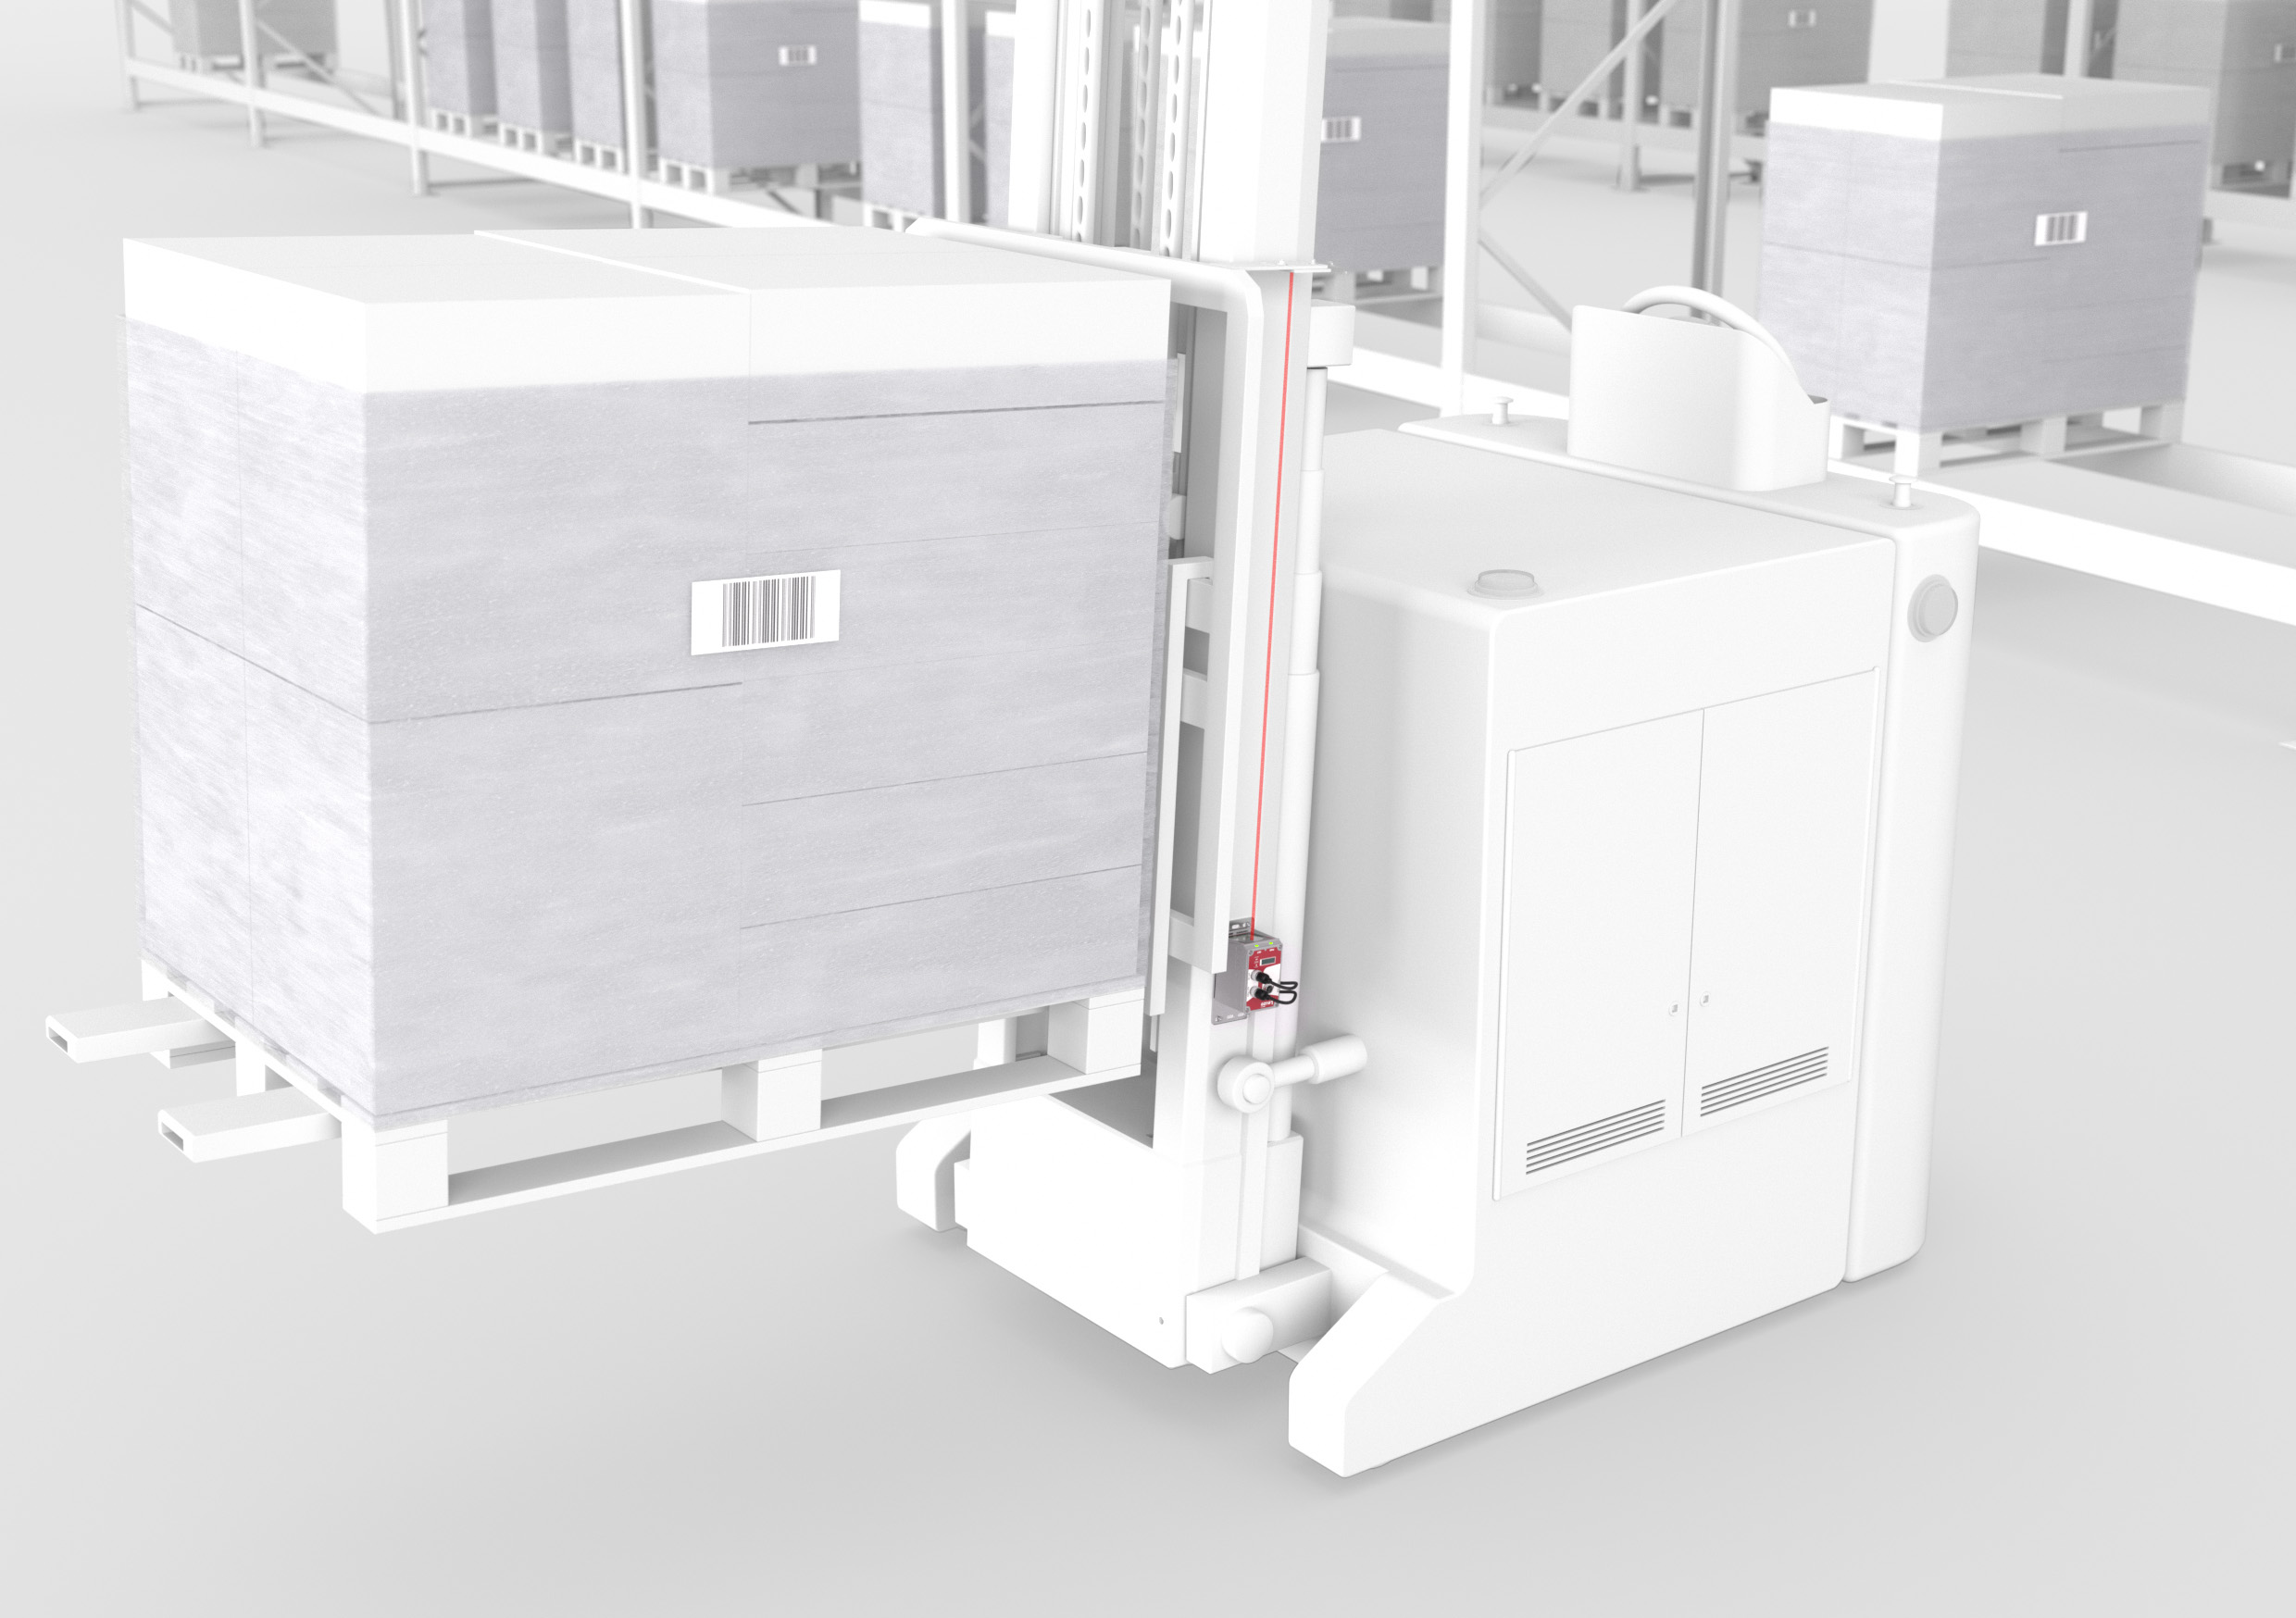
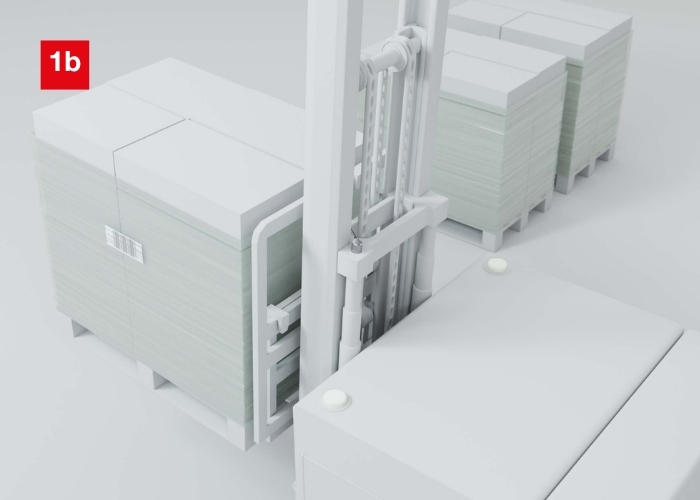
Lift-positioning of the load receptacle
Requirement:
To ensure reliable loading and unloading of a pallet or container, the load receptacle (e.g., the forks) of the vehicle (AGV) must be positioned accurately and consistently along the lifting axis.
Solution:
The AMS 100 laser positioning system delivers measurement data every 2 ms with an absolute accuracy of ± 2 mm. The data can be transmitted directly to the control system or the lifting drive via a wide variety of interfaces.
Positioning of the fork
Requirement:
The lifting axis of the load receptacle (e.g., the fork) must be positioned for loading and unloading repeatably and precisely.
Solution:
An EM series absolute rotary encoder with high accuracy can be used for lift positioning. The data can be transmitted directly to the AGV controller or the lifting drive via standard interfaces.
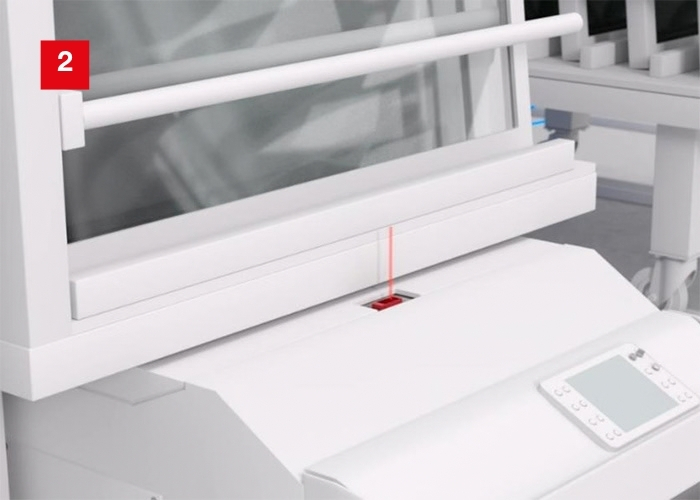
Position / presence detection for locating the load
Requirement:
After the pallet /container has been transferred to the AGV, it must be verified that the load carrier has been positioned correctly. To do this, the presence of the load must be checked at one or more defined positions, as needed.
Solution:
The miniature HT 3C or HT 23 diffuse sensors reliably detect load carriers thanks to their high ambient light sensitivity and active background suppression. The HT 3C series includes many variants for robust solutions, e.g. for detecting objects with colored structure, high-gloss surfaces, and objects with openings.
Fine positioning for picking up load carriers
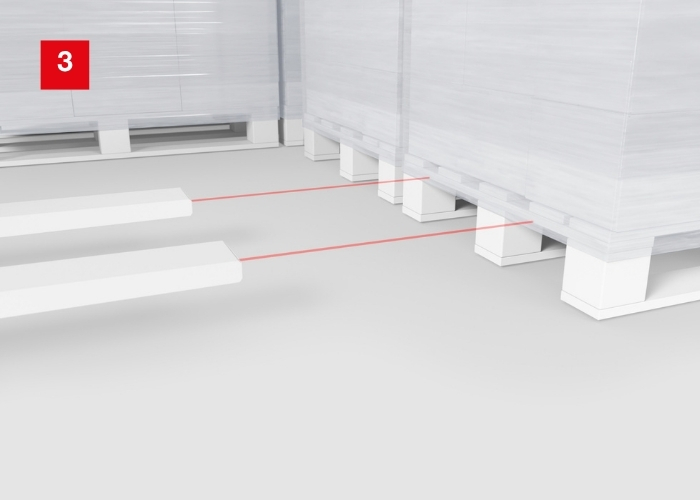
Requirement:
To automatically pick up a pallet or mesh box, the lifting device’s fork must detect the spaces between the feet and ensure they are accessible.
Solution:
Compact diffuse sensors such as the HT 3C can detect objects regardless of material and are also suitable for fine positioning thanks to their precise switching points.
Determining the loading position on the fork
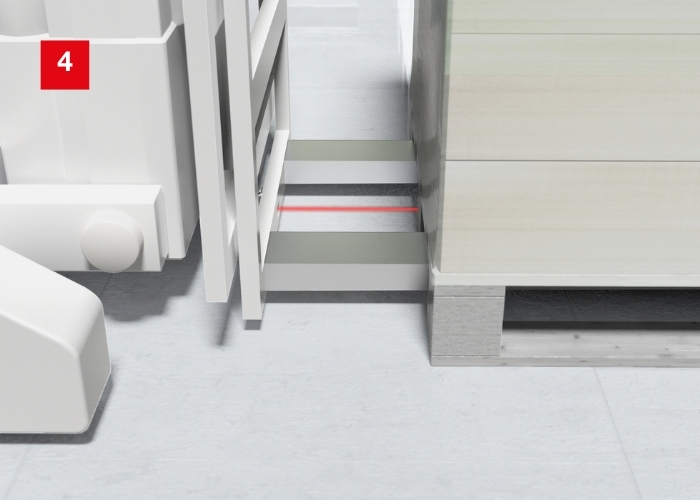
Requirement:
The distance to the front face of the lifting device must be measured to control its forward movement during load pick-up.
Solution:
The ODT 3 or ODT 25 distance sensors reliably detect colors and surfaces with high repeatability using TOF technology. This enables operating ranges of up to several meters with high angle tolerance.
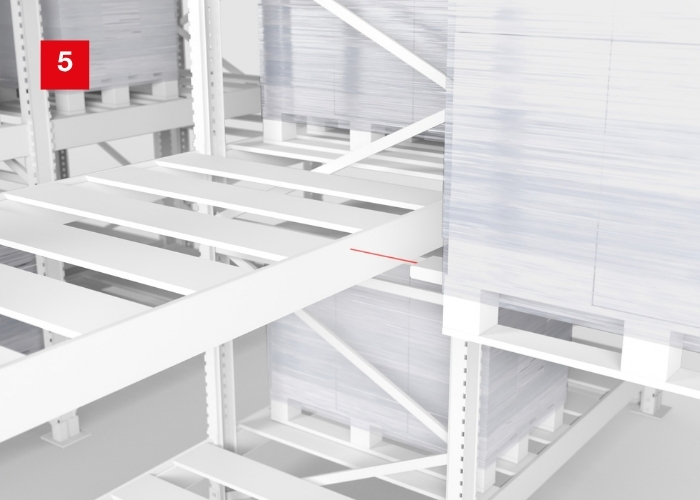
Detection of the upper edge of the shelf rack
Requirement:
For correct storage, the upper edge of the shelf rack on which the object will be stored must be sensed.
Solution:
The compact HT 3C diffuse sensors, which can be integrated into the fork ends, are ideally suited for this task thanks to their precise switching points. Equipped with two switching points, these can also be used simultaneously for fine positioning on the fork.
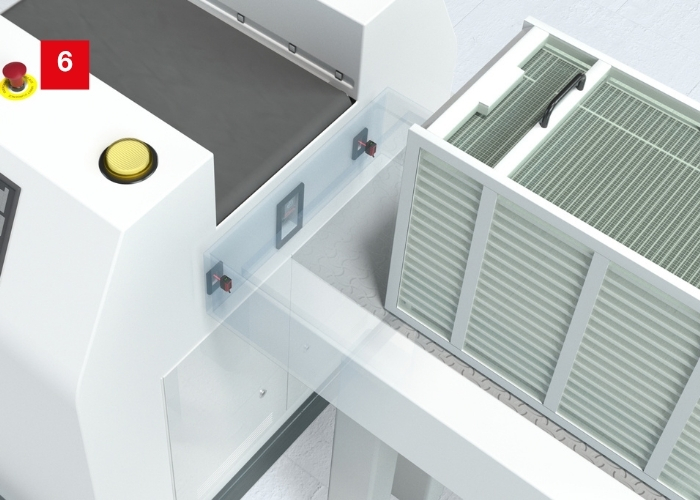
Transport control at automatic transfer points
Requirement:
Automated transfers from mobile to stationary systems and vice versa require contactless signals to initiate the transfer, e.g., from conveyor belts.
Solution:
Compact SR 5B throughbeam photoelectric sensors are ideally suited for this task thanks to their high insensitivity to ambient light and easy alignment using a highly visible red light.
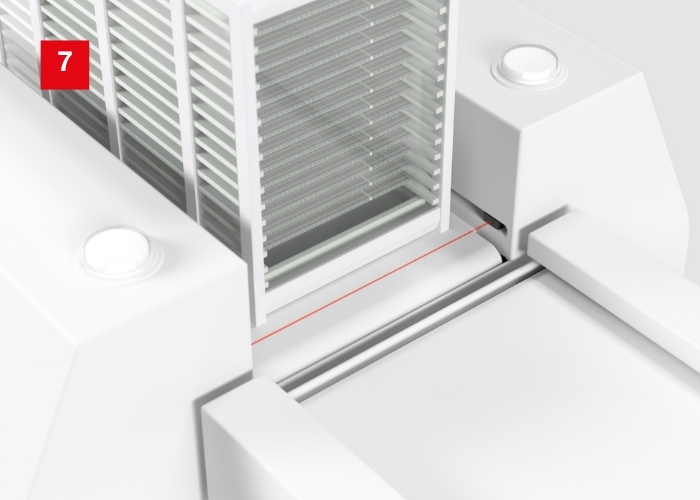
Presence of the transported goods
Requirement:
To ensure reliable transfers, it must be checked that the transported goods has been fully transferred onto or off the AGV.
Solution:
The miniature PRK 23 or PRK 5B reflective photoelectric sensors are easy to integrate and operate particularly reliably with ambient light suppression.
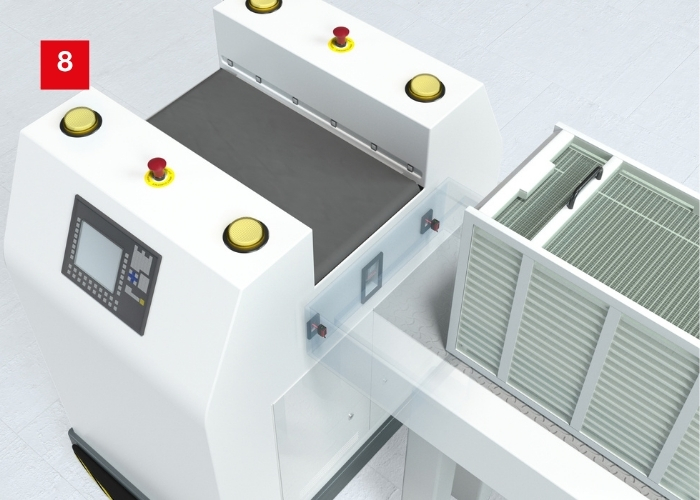
Vibration-free transfer through high-precision fine positioning
Requirement:
In some applications involving fragile objects, extremely precise positioning is required for material transfer, e.g., when a vibration-free transfer is necessary.
Solution:
The camera-based position sensor IPS 200 determines the position relative to a marker at the transfer with an accuracy of up to 0.1 mm. Even the smallest deviations are transmitted via Ethernet-based interfaces to readjust the AGV or the lifting device.
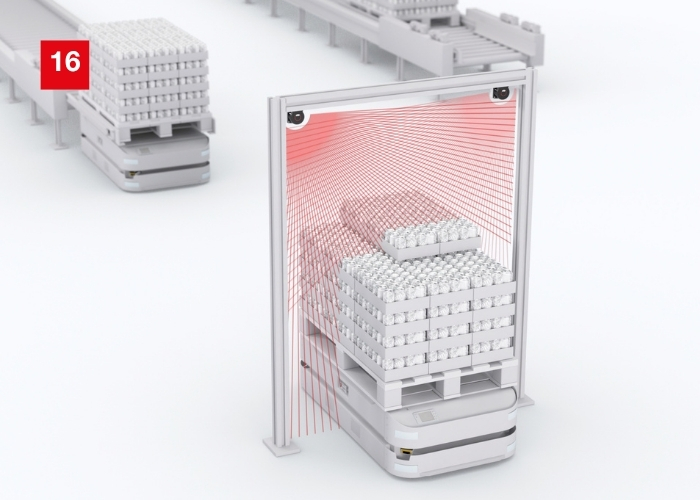
Storage space optimization with volumeGATE
Requirement:
To make optimal use of available storage spaces in a pallet warehouse, the load carriers must be sorted by packing volume and distributed to the appropriate storage locations. This must be detected as the load carriers pass through or drive by.
Solution:
The volumeGATE automation solution combines ROD measuring sensors to measure the package on the AGV with a controller that determines its volume and outer contours, providing a flexible, complete solution for reliable operation. The configurable data is transmitted to the ERP system via Ethernet-based interfaces for further processing and sorting.
Applications for path control and navigation
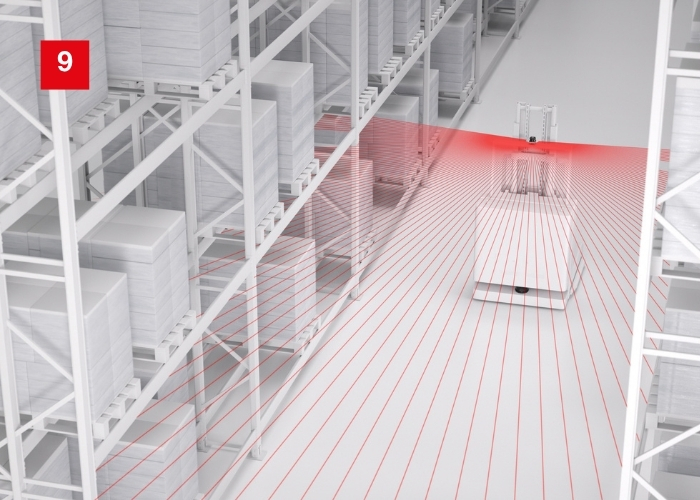
AGV navigation and environmental detection
Requirement:
If the principle of natural navigation is used for the vehicle independently of the safety application, the sensor must provide measurement data for environment detection and further processing in the navigation software at the appropriate quality level. In this case, the safety aspect must be addressed separately.
Solution:
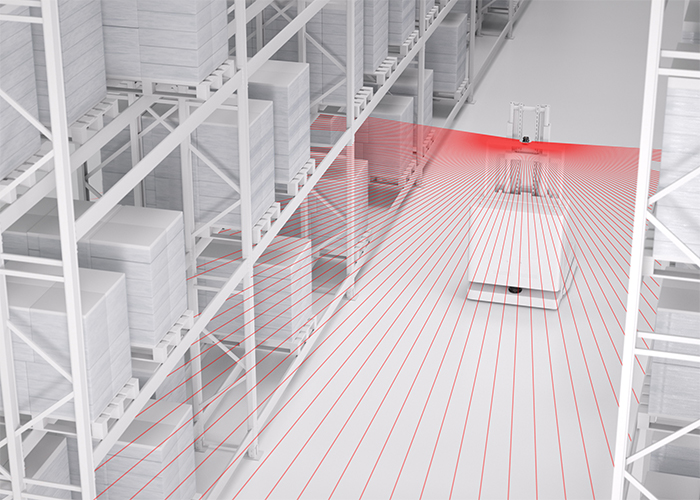
The ROD 300 / ROD 500 measuring laser scanner delivers high-quality measurement data thanks to LiDAR technology, with a minimum angle resolution of 0.025° and an operating range of up to 25 m. This allows a highly accurate map of the surroundings to be created, enabling autonomous vehicles to navigate with precision.
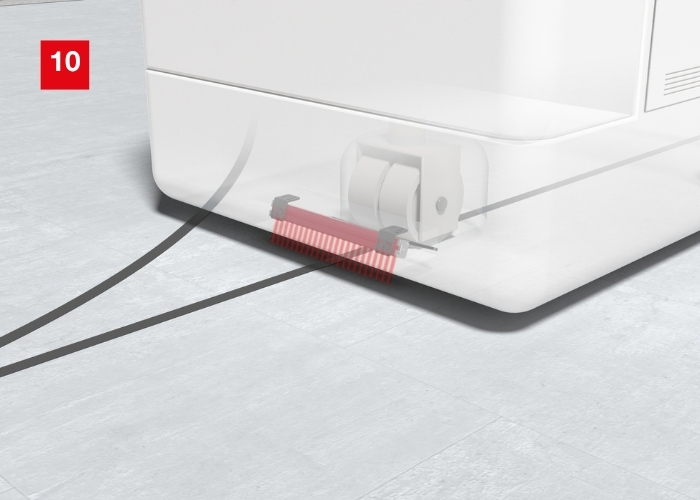
Path control via line tracking
Requirement:
For compact AGVs with a predetermined path marked by a track, the circuit must be controlled. Even particularly low-profile vehicles should be able to be equipped with this system.
Solution:
Using the OGS 600 optical guidance sensor with a ground clearance of just 10 mm, the track edges can be detected and tracked via a signal sent to the vehicle control system.
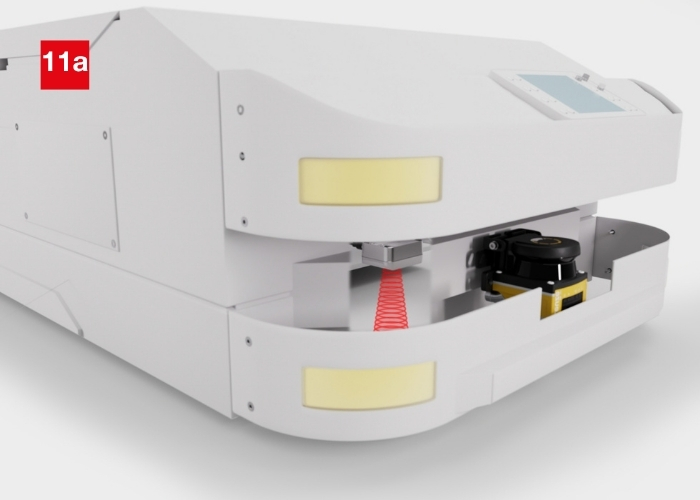
Navigation via RFID references
Requirement:
With the help of transponders embedded in the floor, vehicles can navigate even in damp or dirty environments. These serve as robust reference points that the AGV uses to determine its position and reliably follow the designated transportation path.
Solution:
The RDH 200 readers, with their very compact design and low power consumption, can be easily integrated into mobile transport systems and quickly commissioned. The transponder’s contents are assigned to a defined relative position using a stored table. Based on this, the AGV can navigate and, if necessary, correct its position to move on precisely.
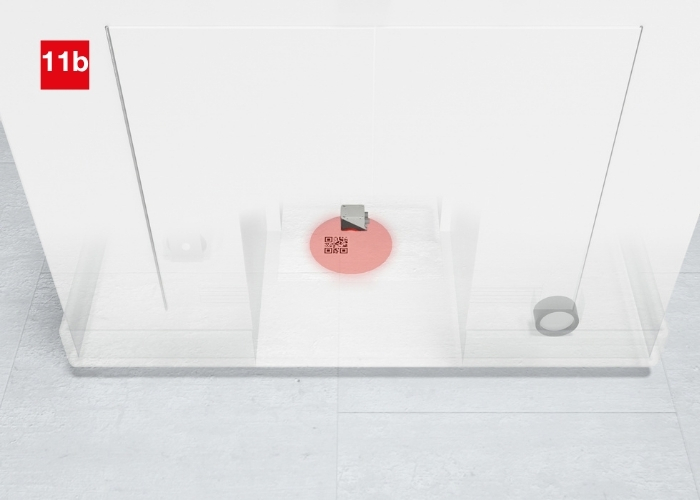
Grid navigation with code labels
Requirement:
Code labels on the ground enable mobile vehicles to navigate precisely along a predefined grid. The defined reference points (codes) allow the vehicle to determine its position accurately and follow designated routes reliably.
Solution:
The compact and easy-to-integrate DCR 200i code reader detects the codes attached to the floor as well as the respective rotation angle as the vehicle passes over them. With a working range of up to 350 mm and a wide range of available interfaces, they enable flexible, straightforward integration into mobile vehicles.
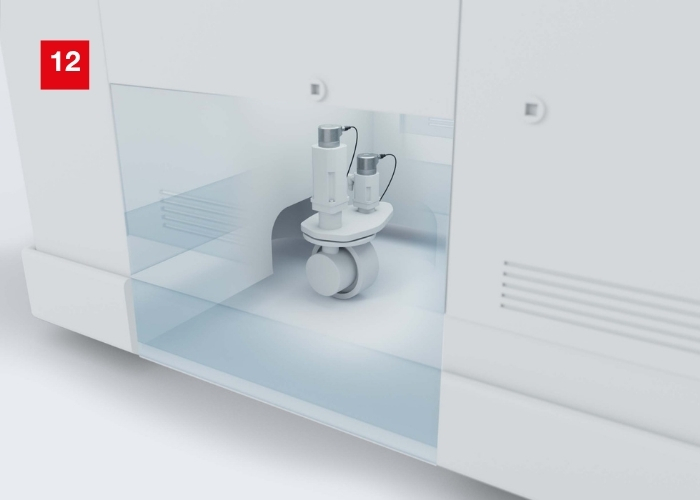
Detection and control of the steering position
Requirement:
The position of the steerable wheels must be determined for navigation and path control. Velocity monitoring is also required and can be combined into the same system.
Solution:
An ES series absolute rotary encoder can be mounted on the side of the steering linkage, while an EI series incremental rotary encoder is used on the AGV’s drive. Both encoders can often be mounted directly on the respective shaft. The detected position values or pulses are transmitted directly to the AGV’s control via suitable interfaces.
Safety applications for AGVs
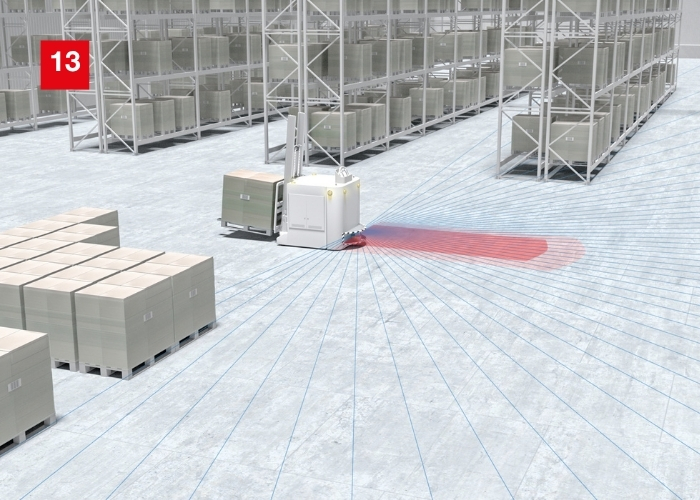
Safeguarding the transportation path and navigation
Requirement:
If the principle of natural navigation is used, the safety sensor must provide the measurement data for the navigation software in order to determine the environment in addition to safeguarding the transportation path in different driving situations.
Solution:
The RSL 200 / RSL 400 safety laser scanner merges safety technology and high-quality measurement value output (navigation) in a single device. It features up to 100 configurable and switchable field pairs. The measurement data have a high angular resolution of 0.1° or 0.2°, which allows a very accurate map of the environment to be created for autonomous vehicles. Alternatively, a device solely for navigation would suffice.
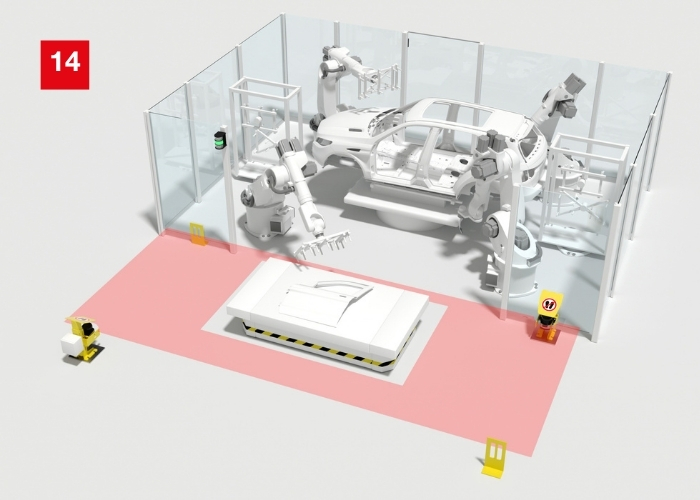
Safeguarding of the transfer station
Requirement:
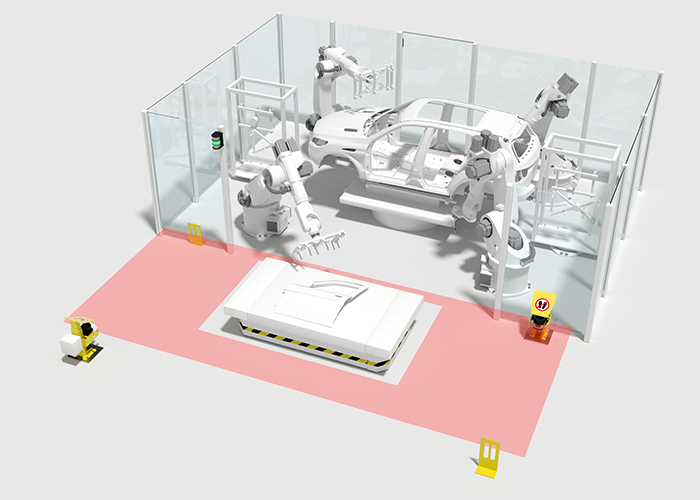
The hazardous area of the robot and the working range of the transfer station must be safeguarded against entry by persons during the entire process. The vehicle must be able to enter and exit the working range fully automatically.
Solution:
As a safety solution, the entire area of the transfer station is safeguarded with RSL safety laser scanners. Their protective fields detect the entry and presence of persons. When a AGV passes through, its outline is dynamically detected and hidden from the protective fields. This allows the AGV to automatically enter the station, transfer the material at the parking position, and then leave the station again. This means that the station remains as safe as can be at all times.
Safety function on the vehicle
Requirement:
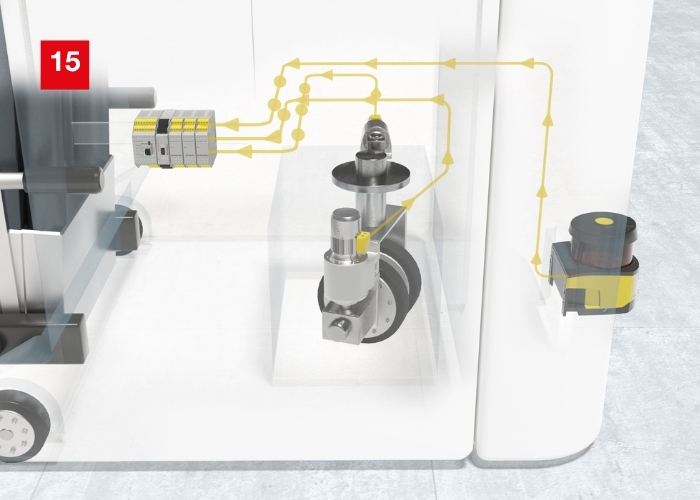
A safety controller is used to record and monitor safety-related parameters such as velocity, steering angle and other driving status data to ensure that the AGV/AMR is functionally safe and operates in a way that is safe for personnel.
Solution:
The compact and modularly expandable MSI 400 safety controller enables safety-related functions to be programmed intuitively and without a license, with the integration of multiple safety sensors. This makes it particularly well-suited for mobile robots or AGVs.
Automated guided vehicles (AGVs): Vehicle types and sensor solutions
Mobile transport vehicles are available in various versions, each of which places specific demands on the sensor systems. Therefore, sensor and detection concepts tailored to the specific vehicle model and intended use are required.
- Towing vehicles (tractor): These are frequently used with guidance systems in large, combined production and storage areas. They follow a predetermined path, such as an inductive or optical guide, and pull skids loaded with materials or goods along a set circuit. Key sensor tasks include path guidance, detection and monitoring of the loads being transferred, stop control, and safeguarding the vehicle’s surroundings.
- Transfer wagons: These vehicles link various production steps and take over standardized, repetitive transport tasks. They are often rail-bound or operate between fixed terminal points. As a result, it is essential to detect their end positions and loads, as well as ensure safety along the route.
- Automated guided vehicles (AGVs): These mobile transport units move along defined transportation paths or navigate autonomously through their operating environment. Sensor systems support navigation, positioning, obstacle detection, load detection, and personal safety.
- Undercarriage vehicles These particularly low-profile transport vehicles drive under a load, lift it, and transport it to its destination. They are often implemented as a type of tow truck or AGV. Key sensor tasks include positioning under the load, monitoring the lifting process, detecting the picked-up load, and safeguarding the transportation path.
The advantages of mobile transport systems lie primarily in their flexibility in the face of changing requirements, as well as in their ability to increase productivity and efficiency. The optimized use of personnel resources also contributes to this. Real-time information on the location and status of goods creates greater transparency, particularly with AGVs, and enables targeted optimization of material flow. In addition, mobile robots can take on additional tasks, for example in production, where they are used for flexible transport and handling processes, among other things.